(Peer-Reviewed) Non-smooth dynamic modeling and simulation of an unmanned bicycle on a curved pavement
Kaiming ZHANG 张凯明 ¹, Xudong ZHENG 郑旭东 ², Zhang CHEN 陈章 ³, Bin LIANG 梁斌 ³, Tianshu WANG 王天舒 ⁴, Qi WANG 王琪 ¹
¹ School of Aeronautic Science and Engineering, Beihang University, Beijing 100083, China
中国 北京 北京航空航天大学 航空科学与工程学院
² Tsinghua Shenzhen International Graduate School, Tsinghua University, Shenzhen 518055, Guangdong Province, China
中国 广东 深圳 清华大学深圳国际研究生院
³ Department of Automation, Tsinghua University, Beijing 100084, China
中国 北京 清华大学自动化系
⁴ School of Aerospace Engineering, Tsinghua University, Beijing 100084, China
中国 北京 清华大学航天航空学院
Abstract
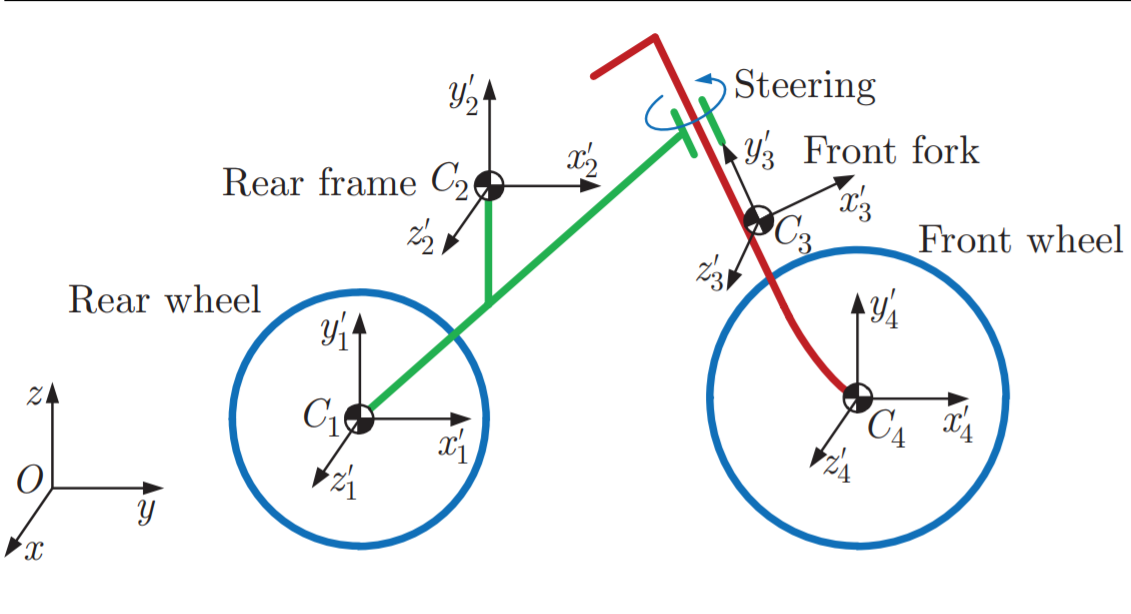
The non-smooth dynamic model of an unmanned bicycle is established to study the contact-separate and stick-slip non-smooth phenomena between wheels and the ground. According to the Carvallo-Whipple configuration, the unmanned bicycle is reduced to four rigid bodies, namely, rear wheel, rear frame, front fork, and front wheel, which are connected by perfect revolute joints.
The interaction between each wheel and the ground is simplified as the normal contact force and the friction force at the contact point, and these forces are described by the Hunt-Crossley contact force model and the LuGre friction force model, respectively. According to the characteristics of flat and curved pavements, calculation methods for contact forces and their generalized forces are presented.
The dynamics of the system is modeled by the Lagrange equations of the first kind, a numerical solution algorithm of the dynamic equations is presented, and the Baumgarte stabilization method is used to restrict the drift of the constraints. The correctness of the dynamic model and the numerical algorithm is verified in comparison with the previous studies. The feasibility of the proposed model is demonstrated by simulations under different motion states.
Electrically switchable bright-field and interference-synthesized edge-enhanced imaging with a polarization-multiplexed metalens
Xiaotong Li, Junhwa Seong, Yeseul Kim, Kwang-Suk Oh, Shiqi Hu, Le Dai, Harit Keawmuang, Beomha Yang, Minseok Choi, Youngsun Jeon, Cherry Park, Weiyan Li, Tianxu Jia, Han Zhu, Xiaodong Cai, Qi Zheng, Jinhui Shi, Young-Ki Kim, Yuchuan Shao, Trevon Badloe, Junsuk Rho
Opto-Electronic Science
2026-09-20
3D-printed copper water cooling system assisted fabrication of 10.6-μm high-power CO₂ laser resistance reflectors
Hongfei Jiao, Binbin Jiang, Xinshang Niu, Yifan Wang, Dongdong Li, Jun Yu, Xiaochuan Ji, Jingjing Xia, Jinlong Zhang, Xinbin Cheng, Zhanshan Wang
Opto-Electronic Advances
2026-09-15
Ultrafast all-optical modulation of wide-bandwidth pulses enabled by silicon-metasurfaces
Kaloyan Georgiev, Khosro Zangeneh Kamali, Anton A. Trifonov, Giulia Crotti, Lyuben Petrov, Stefan Georgiev, Hristo Iliev, Lei Xu, Unai Arregui Leon, Mohsen Rahmani, Giuseppe Della Valle, Ivan Buchvarov, Dragomir Neshev
Opto-Electronic Advances
2026-09-15
Physics-informed neural fields enable blind aberration correction for partially coherent quantitative phase imaging
Shun Zhou, Xingyu Huang, Linpeng Lu, Habib Ullah, Kaiyu Du, Maciej Trusiak, Malgorzata Kujawinska, Yuzhen Zhang, Yao Fan, Qian Chen, Qinrong Zhang, Chao Zuo
Opto-Electronic Science
2026-08-26